Vũ Đức Nguyện

Robotics Software Engineer

DEMO

Multi-Sensor LiDAR–Inertial–GNSS SLAM

2.16 mm
8.0 ms
428
4
C++17GTSAM iSAM2ROS 2 JazzyGazebo HarmonicRVizDockerGitHub Actions
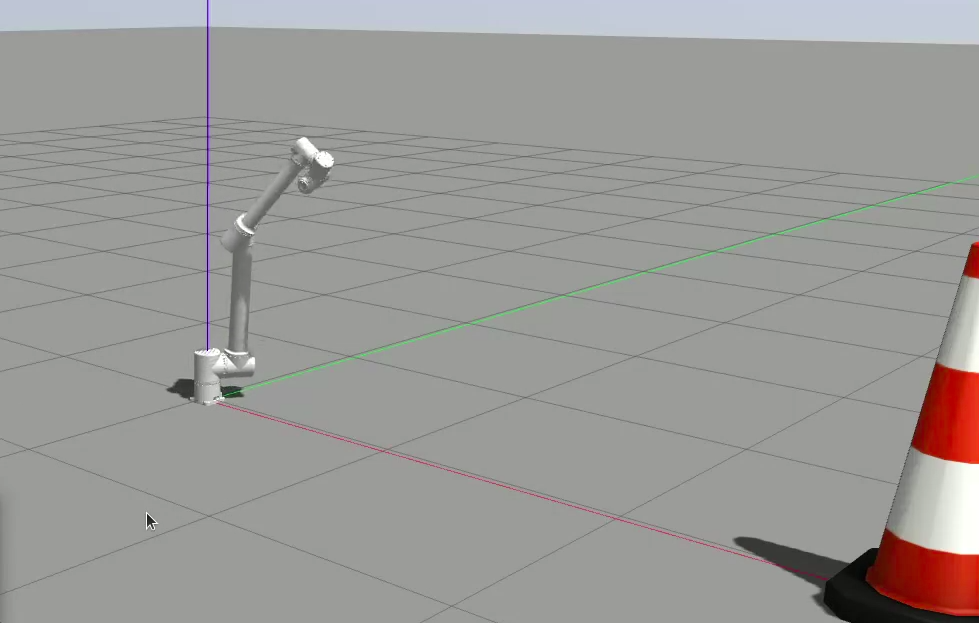
GAZEBO HARMONIC 7-DOF arm in Gazebo Harmonic

0.06 mm
1 kHz
5.3 µs
100%
REFERENCE TIER · PLANNING CONTROL TIER · 1 kHz Goal poseYAML Quintic trajectoryx_d, ẋ_d, ẍ_d CLIK referenceDLS · joint-limitnull space · on q_d Computed torqueτ = M(q)(q̈_d + K_d ė + K_p e)+ C q̇ + G + D q̇ · clamp · hold ImperfectJointInterfacewrite: torque scale, ripple, lag · read: quantise, noise, delay hal::JointInterface · 7-DOF plantSimPlant (bench) | gz_ros2_control (Gazebo) SPSC log ring → CSVeval · Monte Carlo · sweep q_d, q̇_d, q̈_d ττ q, q̇q, q̇
C++17RNEA / CRBAros2_controlGazebo HarmonicMonte CarloDocker arm64
  • 2023

    STM32FreeRTOSPID

  1. 2025 —

    Robotics Software Engineer · FPT Software

    → → → → →

    ROS 2Isaac LabLeRobotGR00TMoveIt 2TwinCAT / ADSJetson ThorDocker
  2. 2023 — 2024

    R&D · Torotic Viet Nam

  3. 2022 —

    Smart Equipment & Robot Lab · HUST

    MiR100AMCLEKF2D LiDAR
  4. 2021 — 2025

SLAM & State Estimation

GTSAM / iSAM2EKF / ESKFIMU preintegrationICPLie groups

Simulation

Isaac SimIsaac LabGazeboMuJoCoRoboDK

Robotics Software

ROS 2ros2_controlMoveIt 2LeRobotACTGR00TPPO

Programming & DevOps

C++17PythonCMakeDockerGitHub Actions

Industrial & Networking

Beckhoff ADSYaskawaDDS / QoSTCP / UDP

Hardware & Embedded

Jetson ThorRPi 5STM32CAN / SPI / I2C